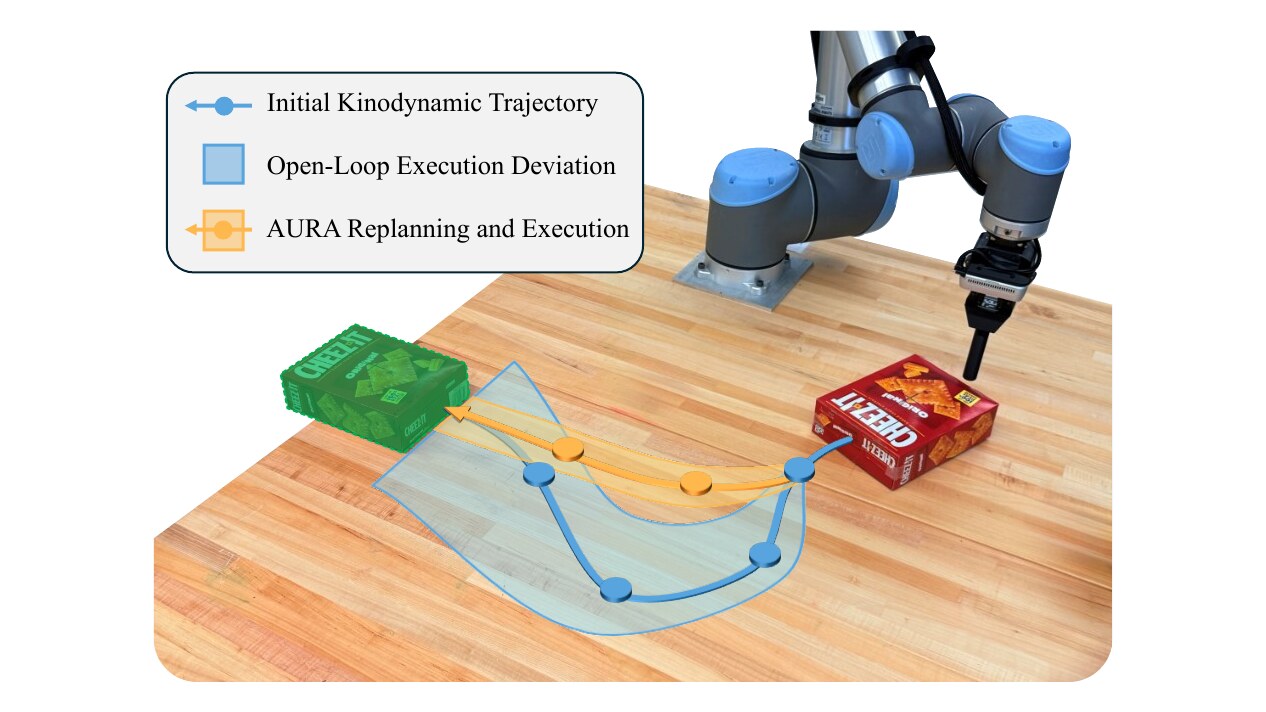
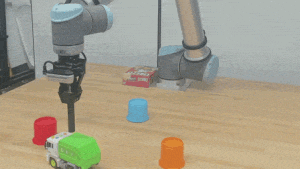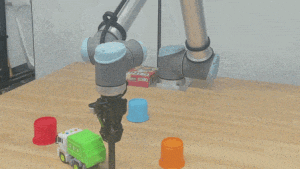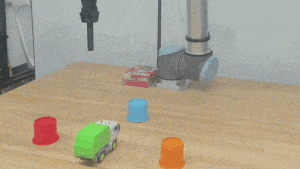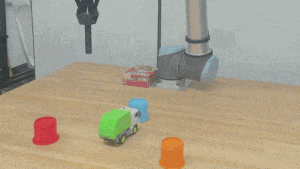
AURA combines asymptotically optimal kinodynamic planning with online replanning and control refinement. Simulation and real-world evaluations show improved trajectory quality and tracking under motion uncertainty.
@article{golestaneh2026aura,title={AURA: Asymptotically Optimal Uncertainty-Robust Replanning Algorithm for Kinodynamic Systems},author={Golestaneh, Seyedali and Zhong, Zhuoyun and Lee, Donghyung and Chamzas, Constantinos},journal={IEEE Robotics and Automation Letters},year={2026},archiveprefix={arXiv},url={https://arxiv.org/abs/2605.27699},note={Accepted},}
MetaPusher: Meta Learning and Planning for Nonprehensile Manipulation of Unseen Objects with Rapid Online Adaptation
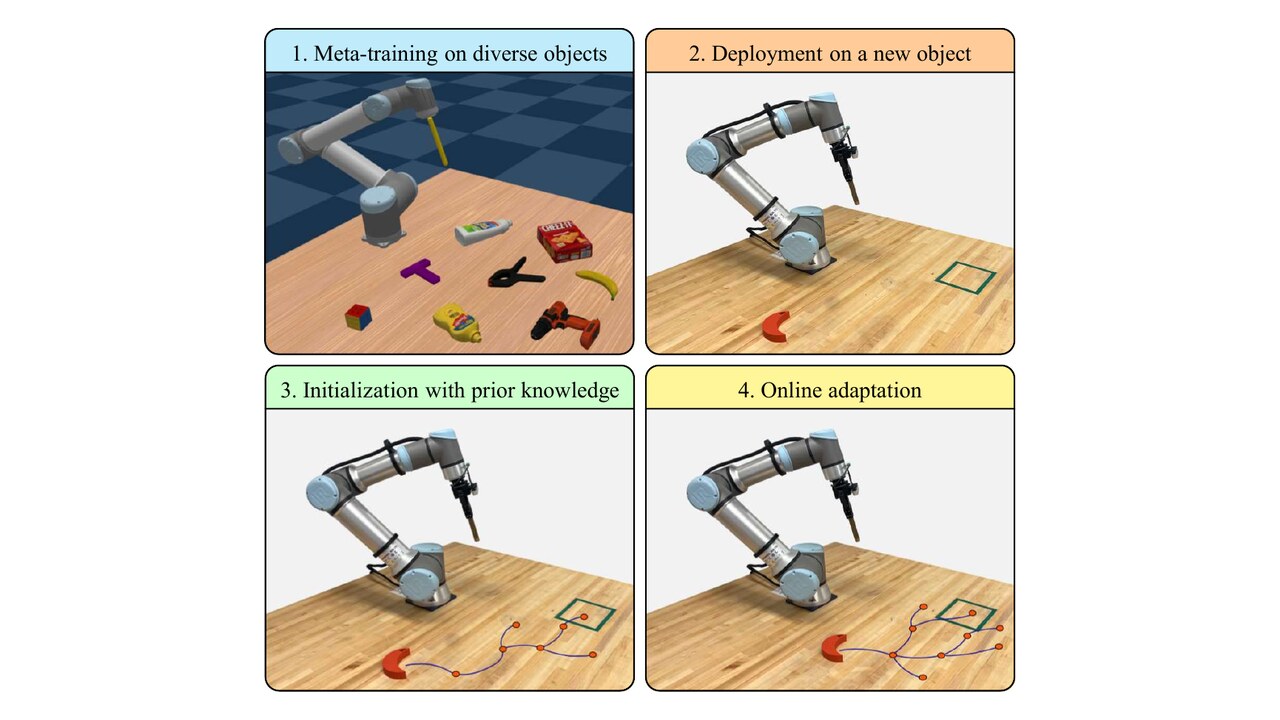
MetaPusher meta-learns manipulation dynamics for unseen objects and adapts its model online while reusing and refining a kinodynamic planner’s search tree. The framework is evaluated in simulation and sim-to-real tasks.
@misc{golestaneh2026metapusher,title={MetaPusher: Meta Learning and Planning for Nonprehensile Manipulation of Unseen Objects with Rapid Online Adaptation},author={Lee, Donghyung and Golestaneh, Seyedali and Singh, Jaskrit and Zhong, Zhuoyun and Kapoutsis, Athanasios and Chamzas, Constantinos},year={2026},archiveprefix={arXiv},url={https://arxiv.org/abs/2609.21122},}
Terminal Matters: Kinodynamic Planning with a Terminal Cost and Learned Uncertainty in Belief State-Cost Space
Zhuoyun Zhong, Seyedali Golestaneh, and Constantinos Chamzas
KiTe adds a terminal-cost objective to asymptotically optimal kinodynamic planning and extends it to belief space. It learns dynamics and uncertainty from data and evaluates goal-reaching performance in simulation and on physical systems.
@misc{zhong2026kite,title={Terminal Matters: Kinodynamic Planning with a Terminal Cost and Learned Uncertainty in Belief State-Cost Space},author={Zhong, Zhuoyun and Golestaneh, Seyedali and Chamzas, Constantinos},year={2026},archiveprefix={arXiv},url={https://arxiv.org/abs/2605.09046},note={Submitted to IEEE Transactions on Robotics},}
CoAd: Constant-Time Planning for Continuous Goal Manipulation with Compressed Library and Online Adaptation
Adil Shiyas*, Zhuoyun Zhong*, and Constantinos Chamzas
CoAd provides constant-time planning over continuous goal-parameterized manipulation tasks using a compressed motion library and lightweight online adaptation. The approach is evaluated across simulated and real-world manipulation tasks.
@misc{shiyas2026coad,title={CoAd: Constant-Time Planning for Continuous Goal Manipulation with Compressed Library and Online Adaptation},author={Shiyas, Adil and Zhong, Zhuoyun and Chamzas, Constantinos},year={2026},archiveprefix={arXiv},url={https://arxiv.org/abs/2603.12488},note={Submitted to ICRA 2027},}
ActivePusher: Active Learning and Planning with Residual Physics for Nonprehensile Manipulation
Zhuoyun Zhong, Seyedali Golestaneh, and Constantinos Chamzas
In IEEE International Conference on Robotics and Automation, 2026
Best Student Paper at ICRA 2026 and HRF 2026; ICRA Planning and Control Best Paper finalist
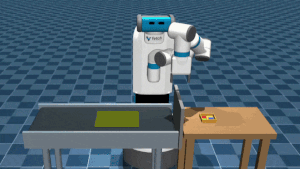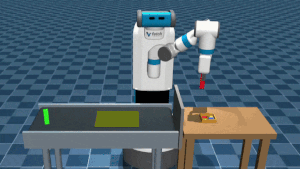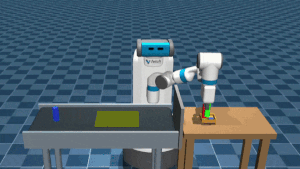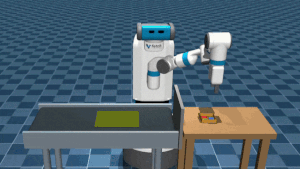
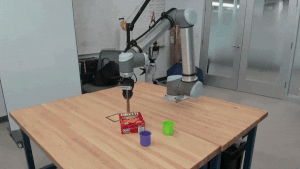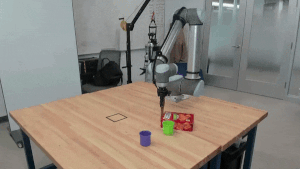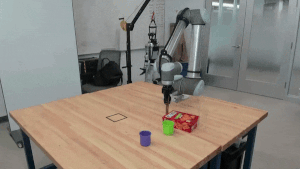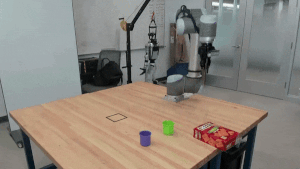
ActivePusher combines residual-physics dynamics learning with uncertainty-guided active data collection and planning for nonprehensile manipulation. Experiments in simulation and on a physical robot show improved data efficiency and planning success.
@inproceedings{zhong2026activepusher,title={ActivePusher: Active Learning and Planning with Residual Physics for Nonprehensile Manipulation},author={Zhong, Zhuoyun and Golestaneh, Seyedali and Chamzas, Constantinos},booktitle={IEEE International Conference on Robotics and Automation},year={2026},archiveprefix={arXiv},url={https://arxiv.org/abs/2506.04646},note={Best Student Paper at ICRA 2026 and HRF 2026; ICRA Planning and Control Best Paper finalist},}
2024
Expansion-GRR: Efficient Generation of Smooth Global Redundancy Resolution Roadmaps
Zhuoyun Zhong, Zhi Li, and Constantinos Chamzas
In IEEE/RSJ International Conference on Intelligent Robots and Systems, 2024
Expansion-GRR uses configuration-space projections and continuity-aware expansion to generate smooth global redundancy-resolution roadmaps efficiently. Simulated and real-arm teleoperation experiments show faster roadmap generation and improved solution quality.
@inproceedings{zhong2024expansiongrr,title={Expansion-GRR: Efficient Generation of Smooth Global Redundancy Resolution Roadmaps},author={Zhong, Zhuoyun and Li, Zhi and Chamzas, Constantinos},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems},year={2024},archiveprefix={arXiv},url={https://ieeexplore.ieee.org/document/10801917},}
2023
A Shared Autonomous Nursing Robot Assistant with Dynamic Workspace for Versatile Mobile Manipulation
Nikita Boguslavskii*, Zhuoyun Zhong*, Lorena Maria Genua*, and Zhi Li
In IEEE/RSJ International Conference on Intelligent Robots and Systems, 2023
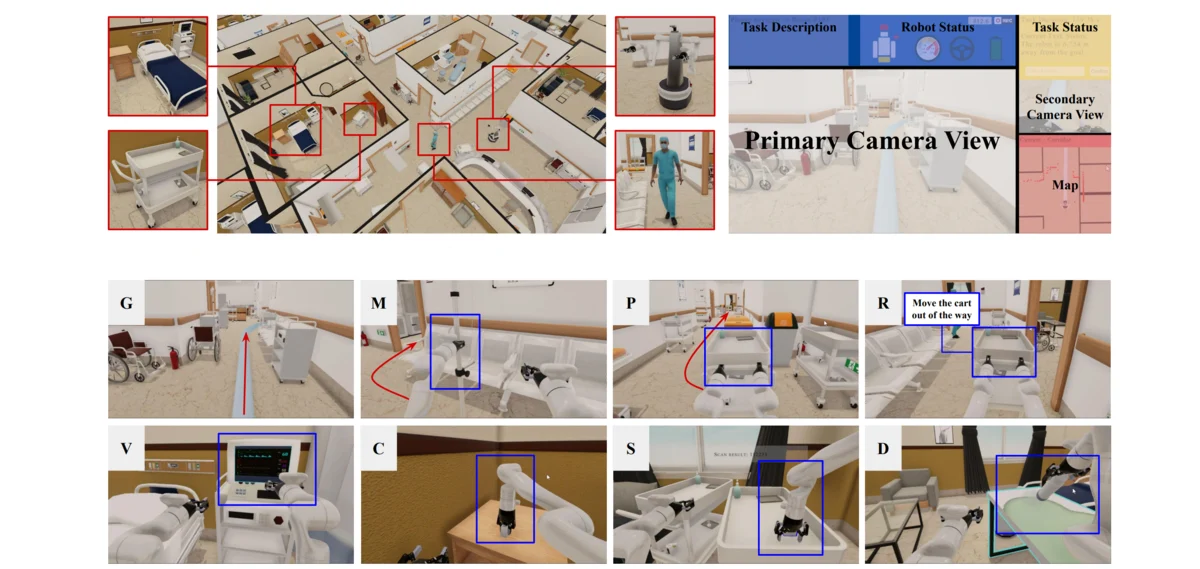
This work presents a shared-autonomy nursing robot assistant with a dynamically managed workspace to support versatile mobile manipulation in care environments.
@inproceedings{boguslavskii2023nursingrobot,title={A Shared Autonomous Nursing Robot Assistant with Dynamic Workspace for Versatile Mobile Manipulation},author={Boguslavskii, Nikita and Zhong, Zhuoyun and Genua, Lorena Maria and Li, Zhi},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems},year={2023},url={https://ieeexplore.ieee.org/document/10342401},doi={10.1109/IROS55552.2023.10342401},note={* Equal contribution}}
Self-Supervised Pre-Training for Robust and Generic Spatial-Temporal Representations
Mingzhi Hu, Zhuoyun Zhong, Xin Zhang, Yanhua Li, Yiqun Xie, Xiaowei Jia, Xun Zhou, and Jun Luo
In IEEE International Conference on Data Mining, 2023
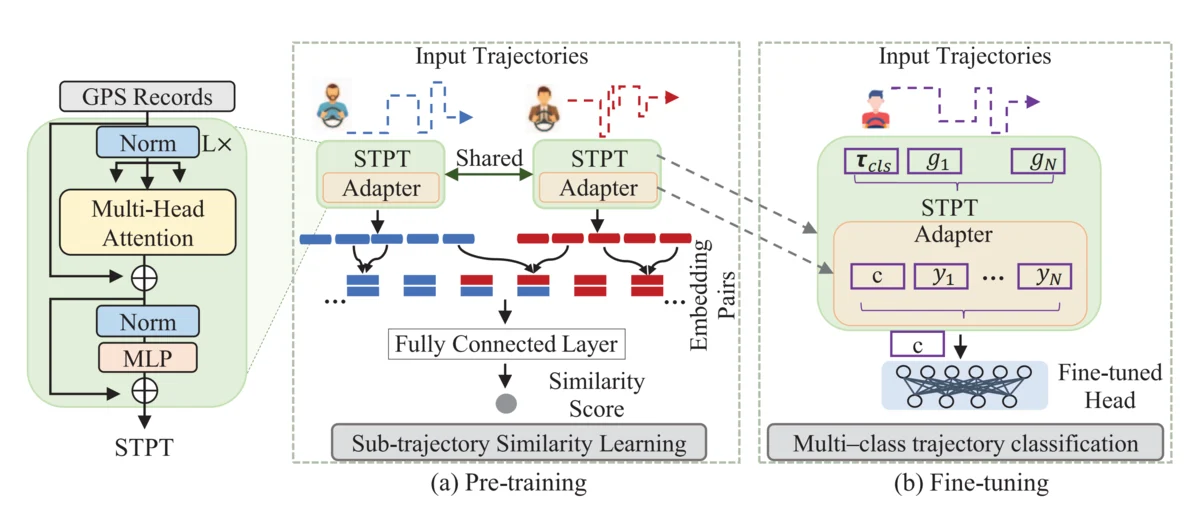
This paper introduces a self-supervised pre-training method for learning robust, general-purpose spatial-temporal representations and evaluates their transfer to downstream prediction tasks.
@inproceedings{hu2023selfsupervised,title={Self-Supervised Pre-Training for Robust and Generic Spatial-Temporal Representations},author={Hu, Mingzhi and Zhong, Zhuoyun and Zhang, Xin and Li, Yanhua and Xie, Yiqun and Jia, Xiaowei and Zhou, Xun and Luo, Jun},booktitle={IEEE International Conference on Data Mining},year={2023},url={https://ieeexplore.ieee.org/document/10415669},doi={10.1109/ICDM58522.2023.00024},}