Zhuoyun (Joey) Zhong
Ph.D. Candidate at Worcester Polytechnic Institute (WPI) · ELPIS Lab
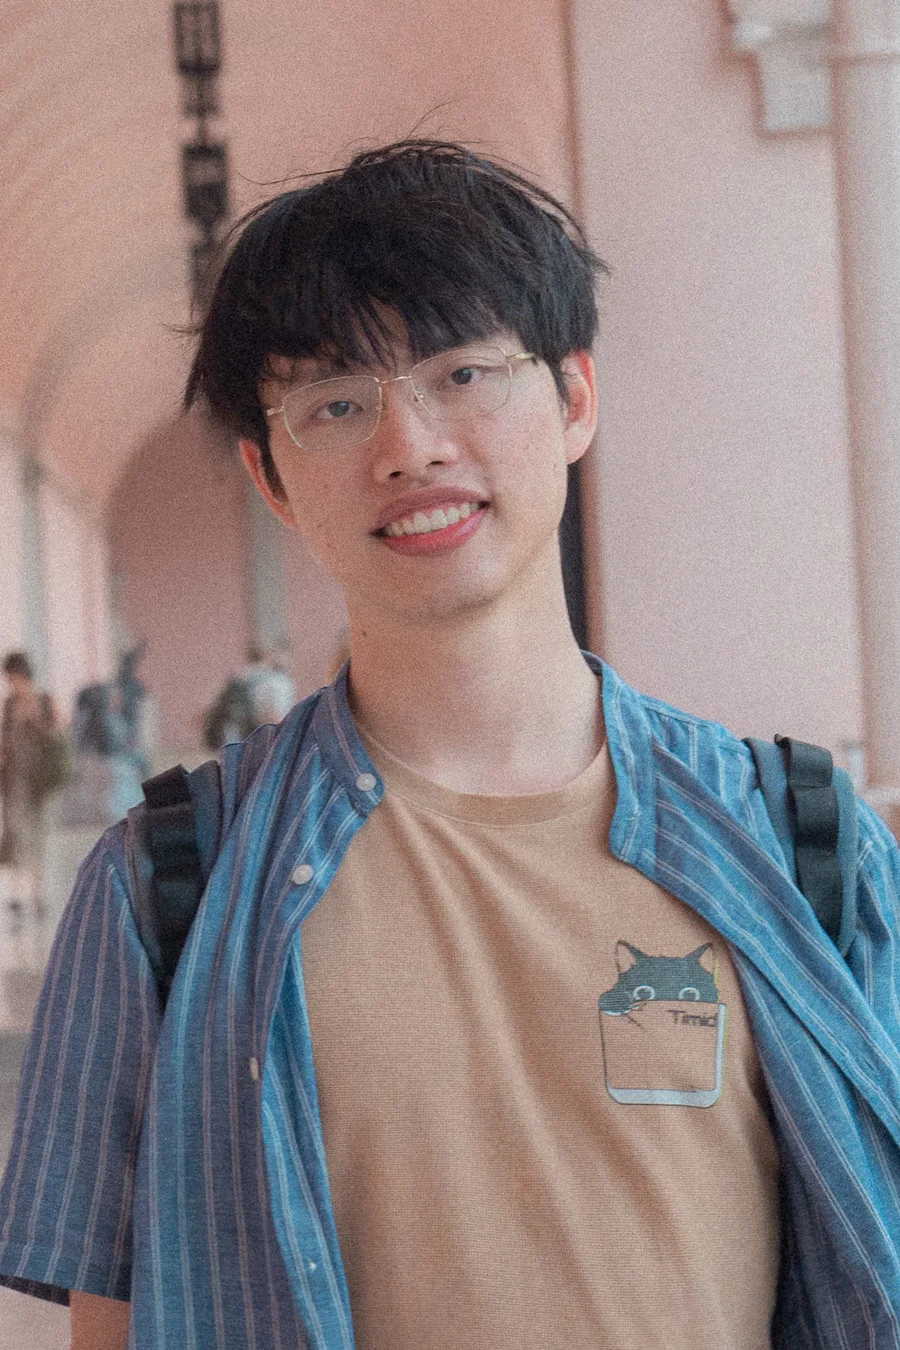
I am a Ph.D. candidate in Robotics Engineering at Worcester Polytechnic Institute, advised by Professor Constantinos Chamzas in the ELPIS Lab. I develop motion planning and robot learning algorithms that help robots act reliably over long horizons, especially when the dynamics and environments are uncertain.
My research spans sampling-based motion planning, humanoid motion planning, active robot learning, and nonprehensile manipulation. I combine classical planning with uncertainty estimates, learned dynamics, and demonstrations to make robot behavior more efficient and adaptable in simulation and on real-world systems.
At ELPIS, I have worked on Expansion-GRR, ActivePusher, KiTe, and CoAd. I am currently working on demonstration-guided humanoid motion planning. My other works include a humanoid building-inspection system developed during my 2026 internship at Siemens, and NurSim, a simulation environment for robotic nursing assistants. For more details of my work and research experience, please refer to my CV.
Before joining WPI, I earned my B.S. in Automotive Engineering from Jilin University.
For questions or collaboration, please contact me via email.